Shi Group · TU Delft
Research
Learning and control methods grounded in theory, with applications to human movement and robotics.
Research area 01
Learning-based optimal control
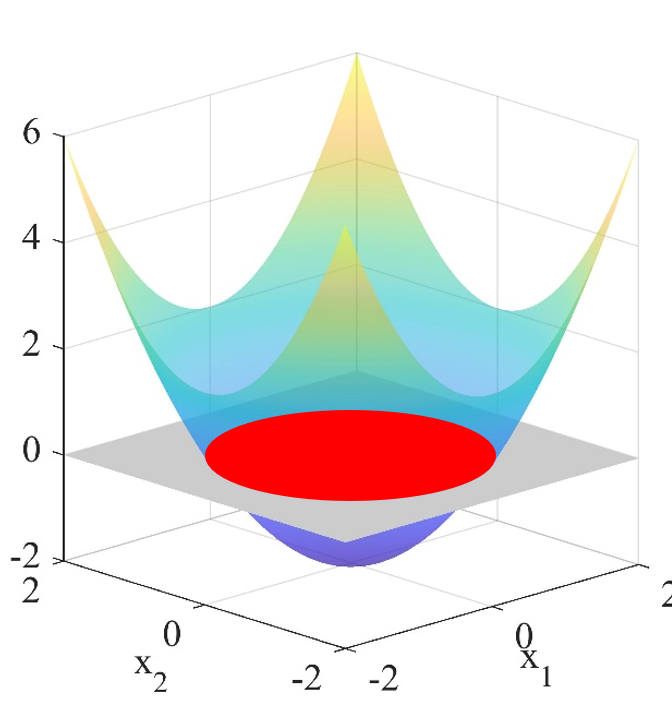
How can we control large-scale or partially unknown systems while retaining rigorous guarantees? We develop and analyze model predictive control, approximate dynamic programming, and control barrier functions, with a focus on performance, safety, and computational efficiency.
Research area 02
Learning-based control for human movement and robotics
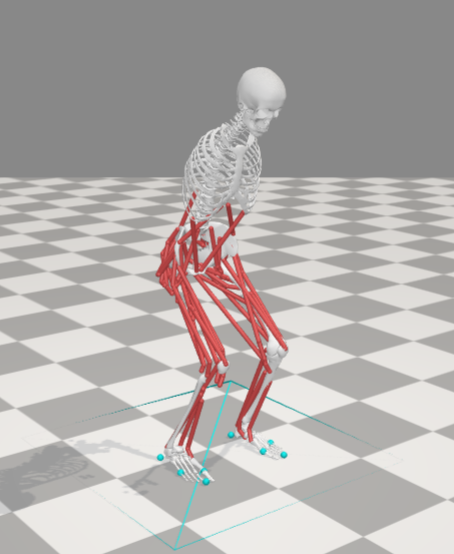
We bring learning and optimal control to nonlinear, high-dimensional systems, particularly human musculoskeletal models and tendon-driven assistive robots. Our work explores reinforcement learning, generative models, and efficient numerical methods for applications in healthcare and human movement.
Human motion simulation
A demonstration from our work on human motion digital twins.
Tendon-driven robotic hand
Teleoperation and vision-based control for manipulation.
Physics-Constrained Human Motion Generation
Qijun Feng · MSc thesis, 2026
Research area 03
Learning dynamical networks
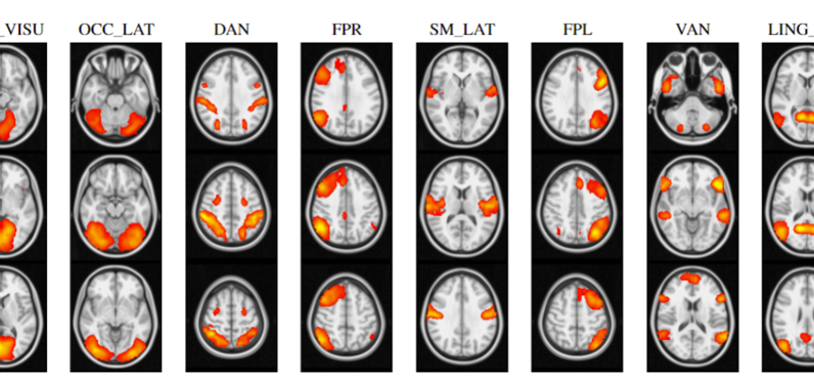
Complex systems consist of interacting subsystems. We study how network structure and dynamics can be identified from limited measurements and excitation signals, with applications including effective connectivity in brain networks.